Underactuated Self-Balancing / Smart Car KitProduct Brochure
Balancing Robot
Underactuated Spherical Balance Control
Product Details
Product Overview
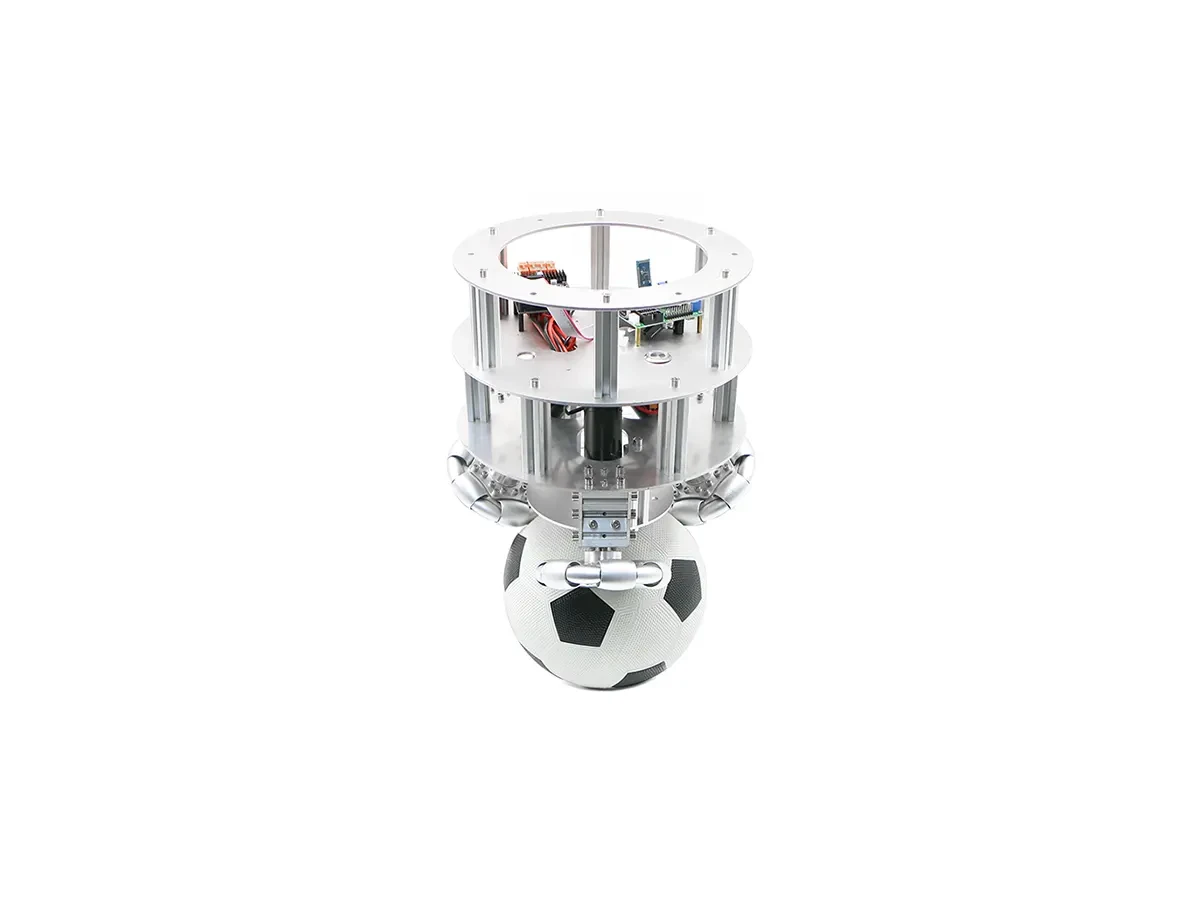
A ball-balancing robot is a classic underactuated system: it adjusts its attitude solely through single-point contact between the sphere and the ground. Its control law design is more complex than that of two-wheeled self-balancing robots, making it an ideal testbed for modern control theory and nonlinear control research.
Two models feature a DC brushed motor and a stepper motor, respectively, allowing students to compare the response characteristics of different actuators on the same platform. The controller includes reserved CAN and 5V/5A output interfaces for connecting external sensors.
Other models in the same series
Key Features
- Underactuated spherical walkers are harder to control than two-wheeled balancers, making them ideal for algorithm research.
- Two models equipped with a DC brushed motor and a stepper motor, respectively, to compare different actuator characteristics.
- Protects the battery and CAN expansion interfaces in a rugged housing; supports secondary development.
Typical Applications
- Modern Control Theory Lab Experiment
- Design and Validation of Control Laws for Underactuated Systems
- Actuator Feature Comparison Study
Technical Specifications (7Item
- Dimensions
- Diameter 406.1×484.3mm / Diameter 222.4×322.5mm
- Total Weight
- 4.17kg / 1.74kg
- Drive Motor
- MD36P27 12V DC Brushed Motor / MS42C Stepper Motor
- Battery
- 12.6V 5100mAh / 12.6V 2550mAh (with protective case)
- Battery Life
- About 90 minutes / About 30 minutes
- Controller
- STM32F407VET6 / STM32F103RCT6
- Extension Interface
- CAN interface, 2 5V/5A output interfaces