Large-scale ROS research robotProduct Brochure
T280 Brushless 4-Wheel Drive Robot
Four-Wheel Independent Drive and Steering
Product Details
Product Overview
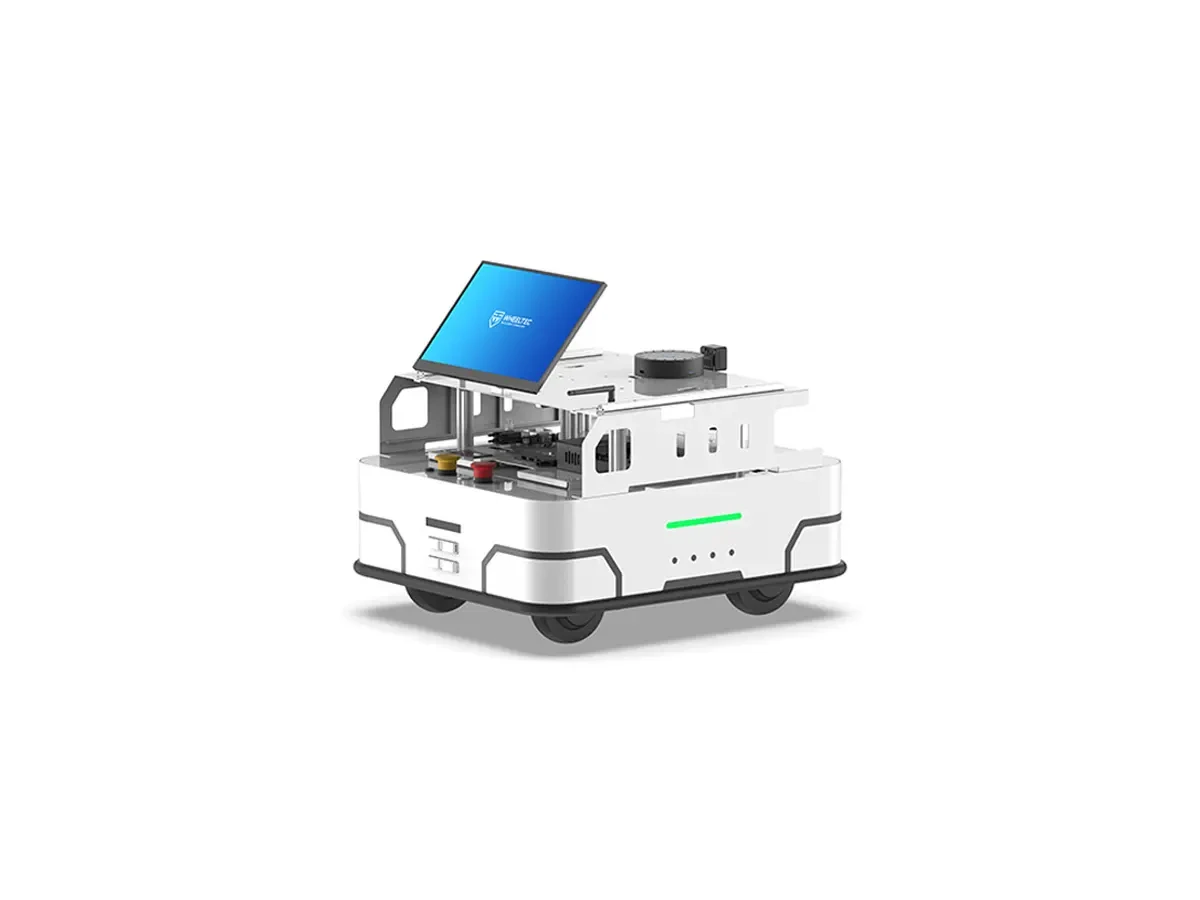
T280 is a four-wheel, four-steering mobile chassis designed for embodied AI. Each wheel features independent drive and steering with a ±170° range and mechanical stops, enabling specialized maneuvers like in-place turning and crab walking.
The drive uses a servo hub motor. Steering is executed by a brushless servo motor with absolute encoder feedback for angle measurement. The LiDAR can be configured as single-line or 32-line multi-line, facilitating mapping, navigation, and multimodal perception research.
Other models in the same series
Key Features
- Four independent wheel drives + four independent wheel steers: enables in-place turning and zero turning radius.
- Servo hub motor with absolute encoder feedback; steering angle ±170° (with limit switches)
- LiDAR options: M10P single-line or Wanshi 32-line multi-line, compatible with embodied AI algorithms.
Typical Applications
- Embodied AI and Large Model-Driven Mobile Manipulation Research
- Omni-directional Kinematics Validation in Complex Terrain
- Multi-line LiDAR Mapping and Localization Experiment
Technical Specifications (12Item
- Dimensions
- 640×542×389.1mm
- Chassis curb weight
- 50 kg
- Tire
- Diameter 103mm, tread width 38mm
- Track / Wheelbase
- 330mm / 428mm
- Maximum Speed
- 2.0m/s
- Maximum Grade
- 20°
- Maximum Obstacle Clearance Height
- 40mm
- Steering Capability
- Steering angle ±170° (with limit), capable of in-place turning
- Drive Motor
- 4× Servo Hub Motor, Rated Voltage 24V, Single Motor Rated Power 120W
- Steering Motor
- 4× Brushless Servo Motor with Absolute Encoder Position Feedback
- LiDAR
- None / M10P Single Line / Wanjie 32 Multi-Line (Optional)
- Battery
- 2 4V LiFePO4 battery pack, capacity selected based on configuration